Universal Robots presented Gen 7 this week. A notable improvement is the new tool flange, which routes data, power and safety signals directly to the tool. As a result, fewer loose cables hang around the wrist.
The cable question remains
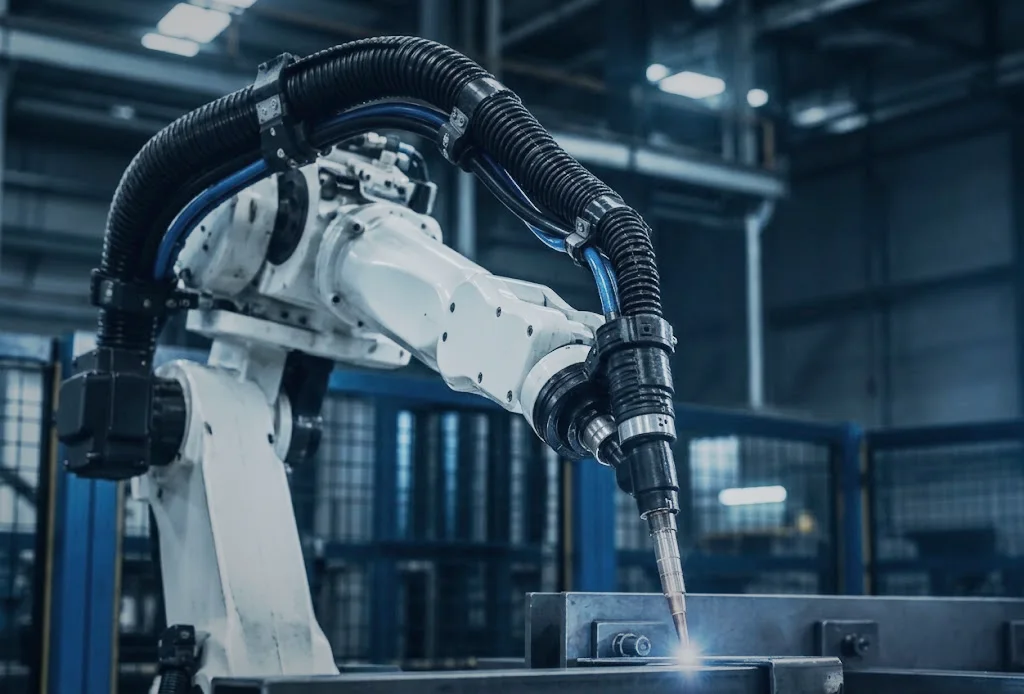
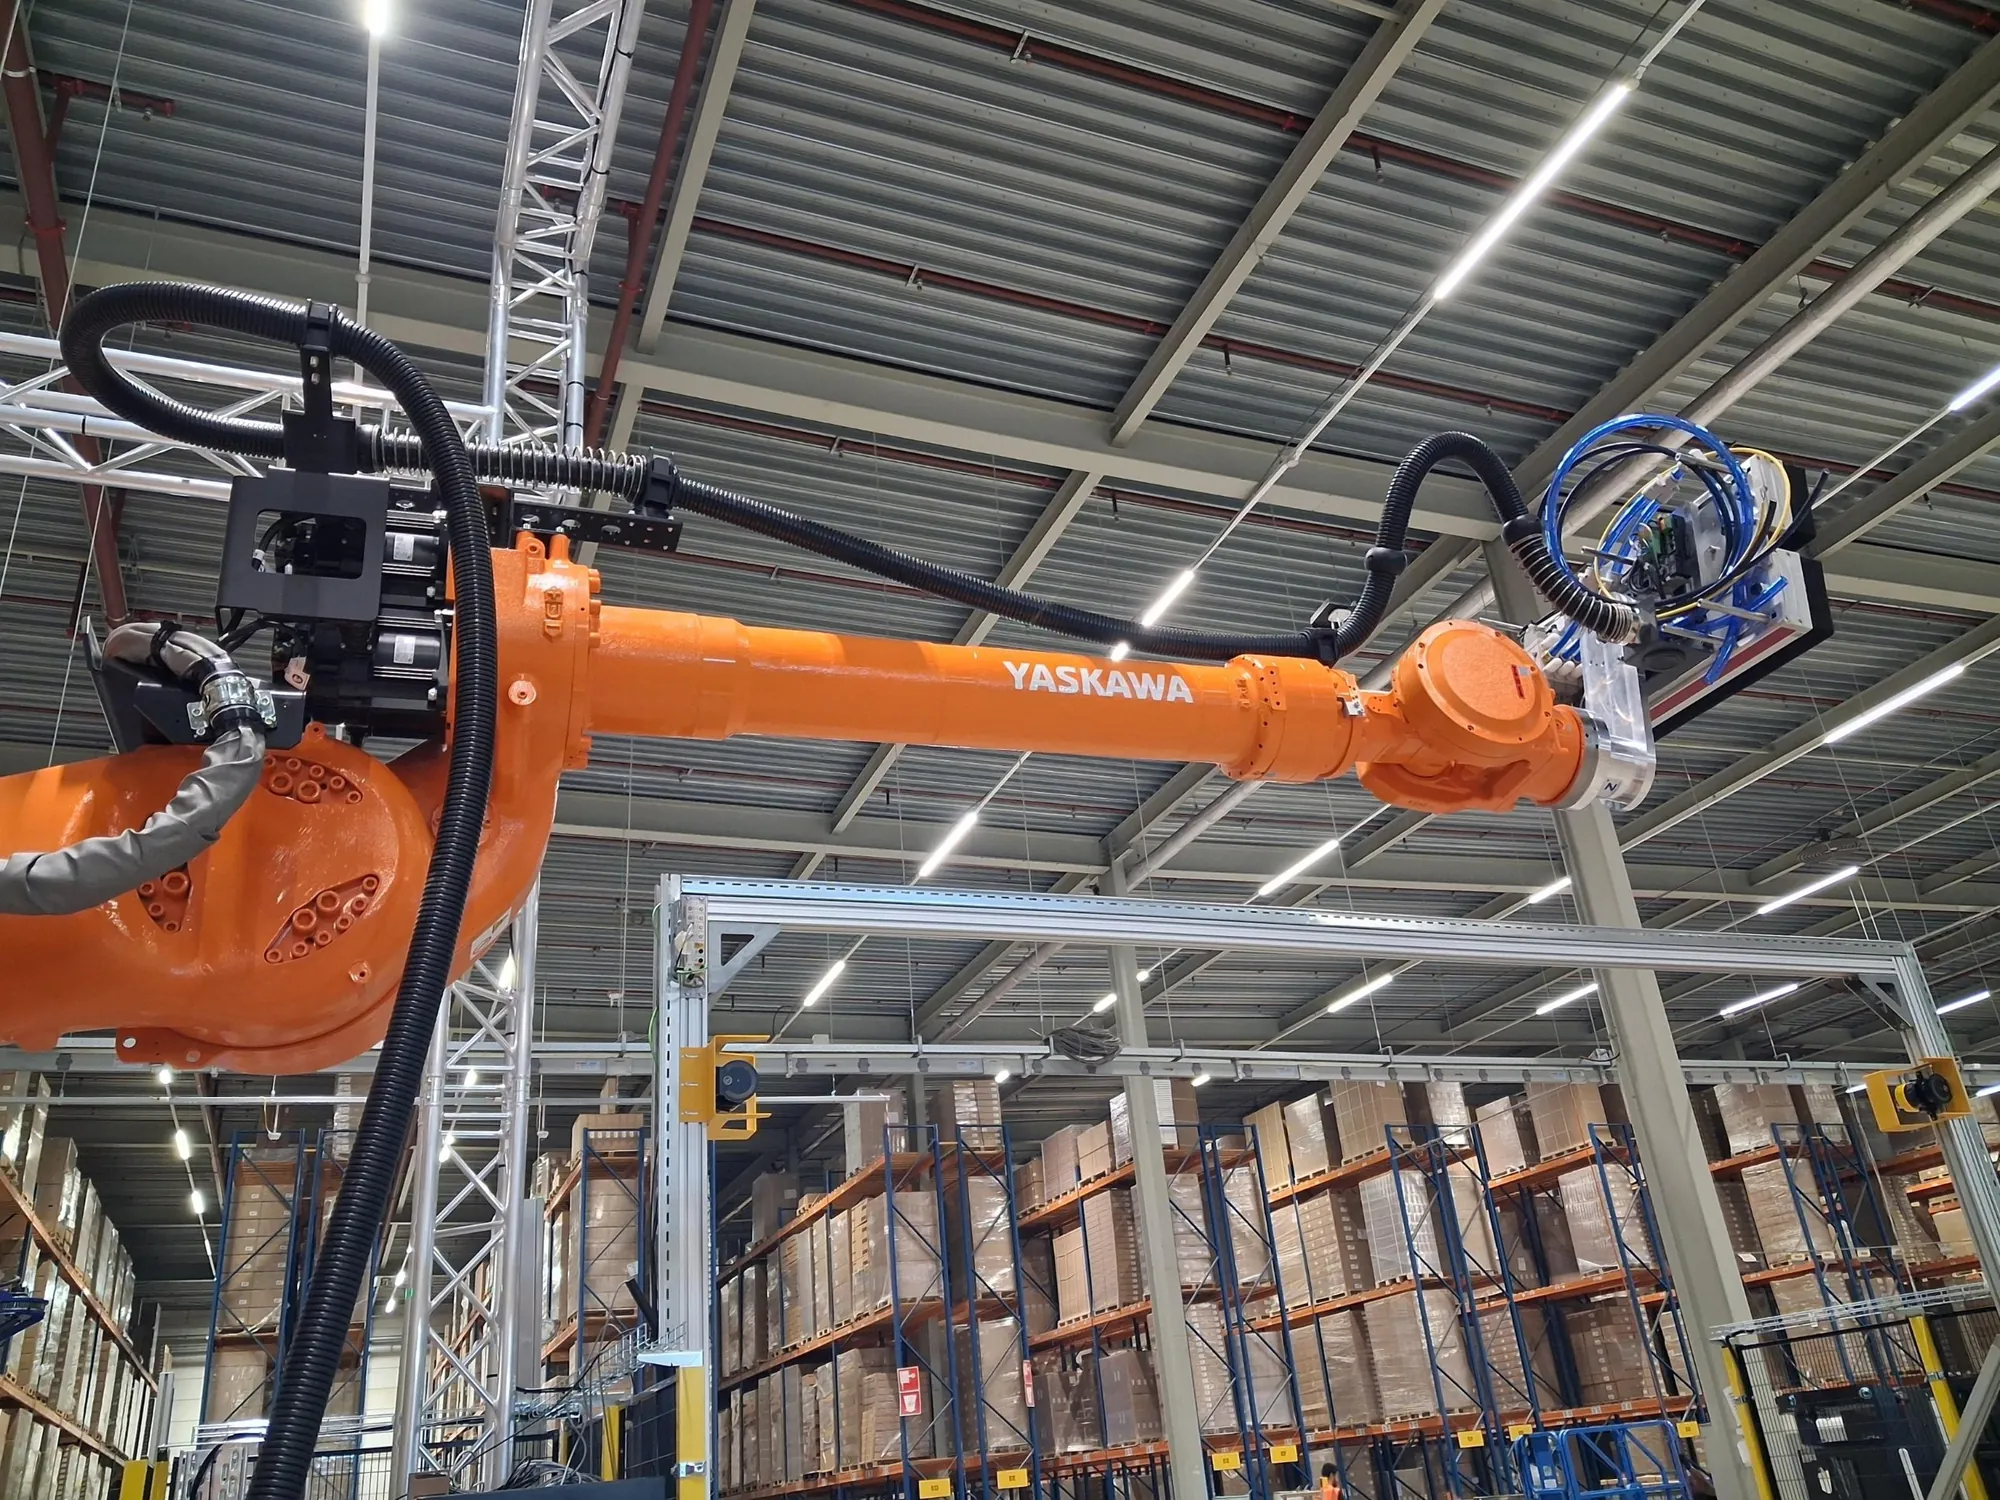
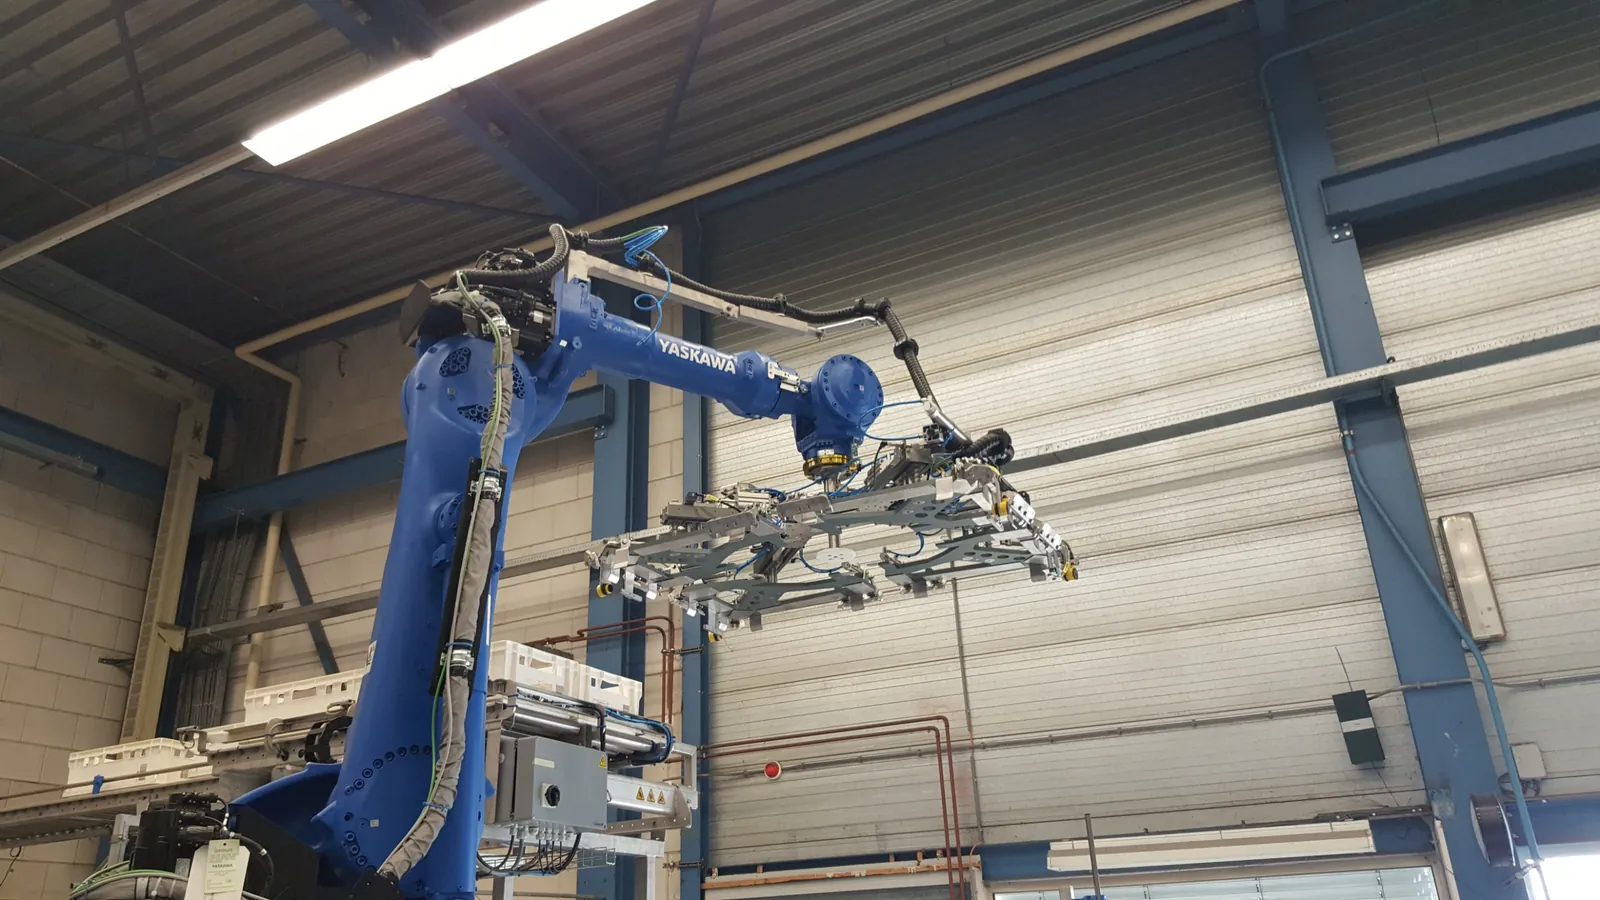
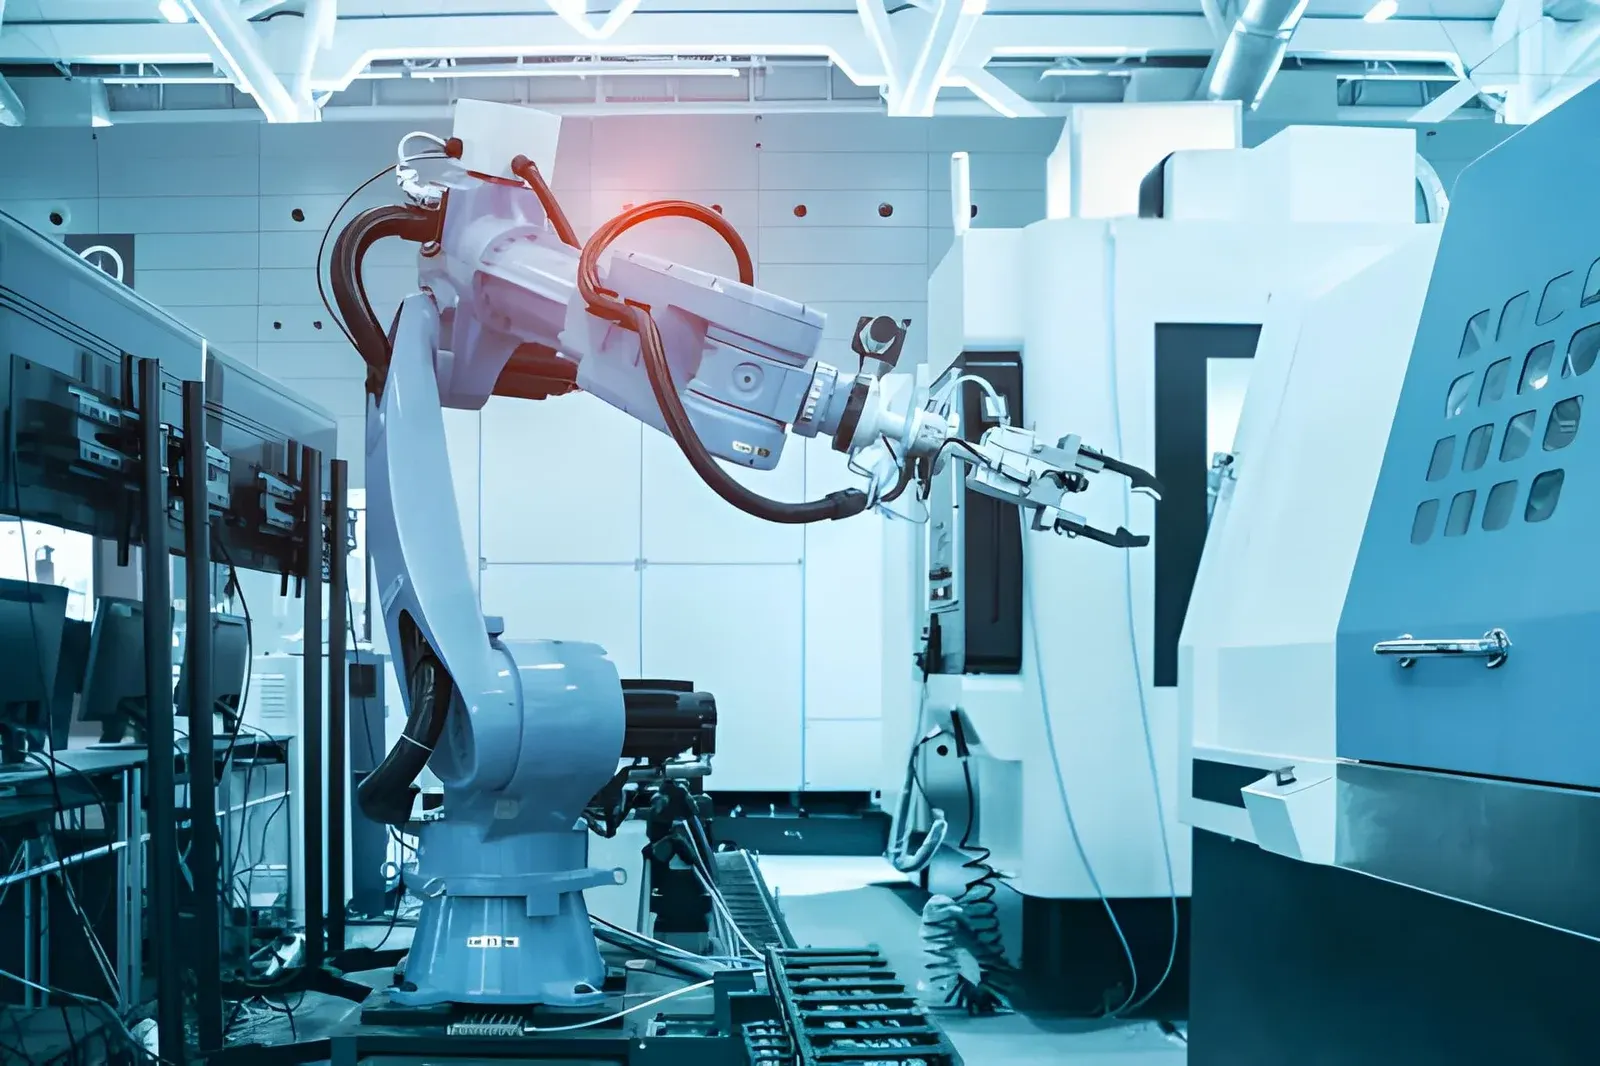
That is a good step, but it does not make the cable issue go away. As soon as compressed air, vacuum, adhesive supply or an extra sensor is added, a bundle runs along the arm again. Around axes 4 to 6, most wear is caused by torsion and rubbing.
What to look for with a cobot
- Torsion at the wrist: axis 6 often rotates a long way. The bundle must be able to follow that rotation without kinking.
- Retraction: a hose that hangs too loosely strikes the arm or the workpiece. A retraction system keeps it taut without tensile stress.
- Mounting: holders must guide the hose without restricting the cobot's freedom of movement.
- Safety: with a cobot, people work close by. A tightly guided package prevents snagging and trapping.
Engineering based on the motion envelope
At Wisman Techniek, we engineer and assemble Reiku dress packs for robots and cobots. We start with the working envelope and then define bending radii and mounting points. With a good dress pack, lines last longer and you prevent downtime.
Calculate it yourselfDress pack configuratorConfigure a dress pack for your robotOpen the dress pack configurator